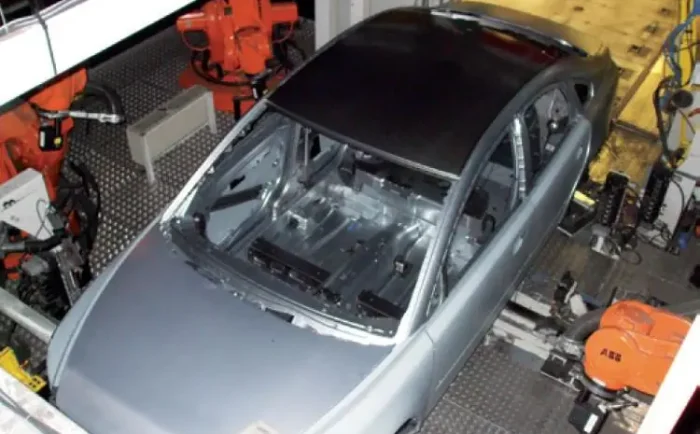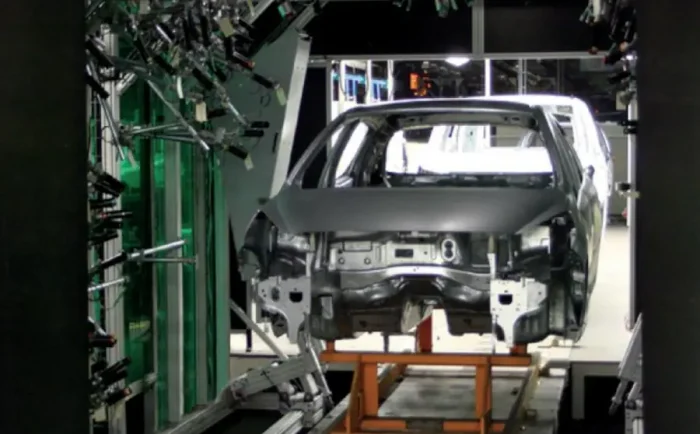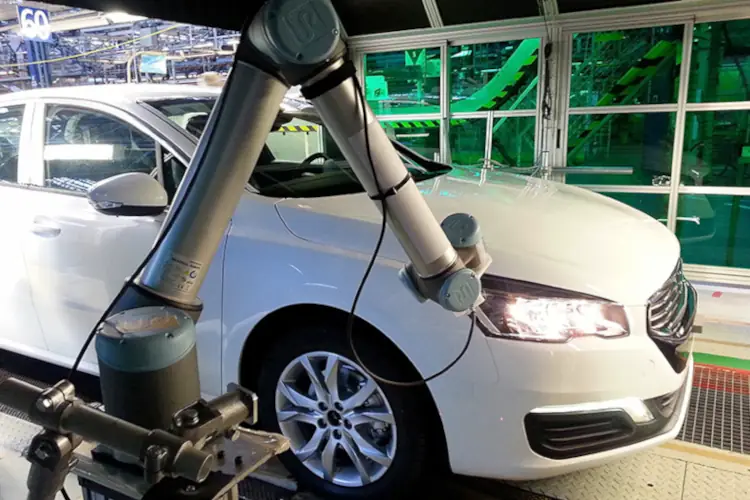
Collaborative robot station for gap and flush measurement for multi-materials
Inspection during the assembly of unpainted and painted metal sheets.
Working principle:
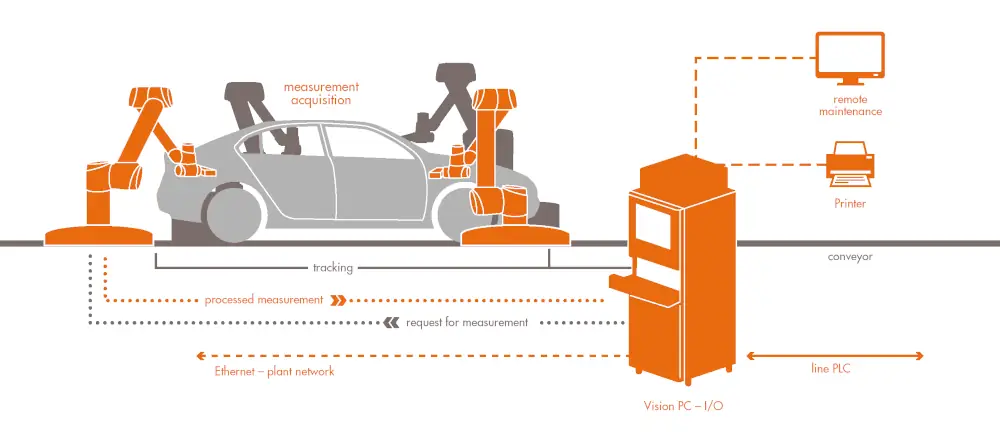
Upon arrival in the station, the vision system determines the positioning of the vehicle with respect to the robots. A correction of their trajectories is carried out. Each of the robots then follows their trajectory as the vehicle moves in the station. For each section to be analysed, an image is taken instantly and is
transmitted to the processing unit. The calculation algorithms extract the measurements and compare them with the parameterized tolerances. The verdict is passed on to the manufacturing process. A synoptic displays the results by indicating their location and nature by using a colour code: red (NOK), orange (within the tolerance limits), green (OK) -for each section.
Related products
-
Smart Scan
Configurable scanner for easy and accurate acquisition with cost efficiency (more…)
-
Easy Wheel
Easy Wheel is a multi-task Phased Array scanning device for effortless heavy duty inspections (more…)
-
Thickness Tool
20 times faster and accurate thickness mapping of blended-outs overall aircraft skin
-
Rivet Inspect
Simplify manufacturing inspection and reduce inspection time with automated control of rivet positioning (more…)